ROCOS
An open robot control system.
A modular control stack connecting robot applications, EtherCAT devices, and a visual programming interface.
Motion control · System integration · Open source
Explore ROCOSRobotics researcher.
I build robot control systems for precise motion, compliant interaction, and real-world experiments.
Shenyang Institute of Automation
Chinese Academy of Sciences
The preview is unavailable. Open the full project
From the control stack
to the physical machine.
An open robot control system.
A modular control stack connecting robot applications, EtherCAT devices, and a visual programming interface.
Motion control · System integration · Open source
Explore ROCOSSeven axes. Shared space.
A collaborative robot with joint torque sensing and ROCOS control, built to explore compliant motion and human–robot interaction.
With Yunxiang Jiang · Manufacturing: Landau Robotics
Meet TALON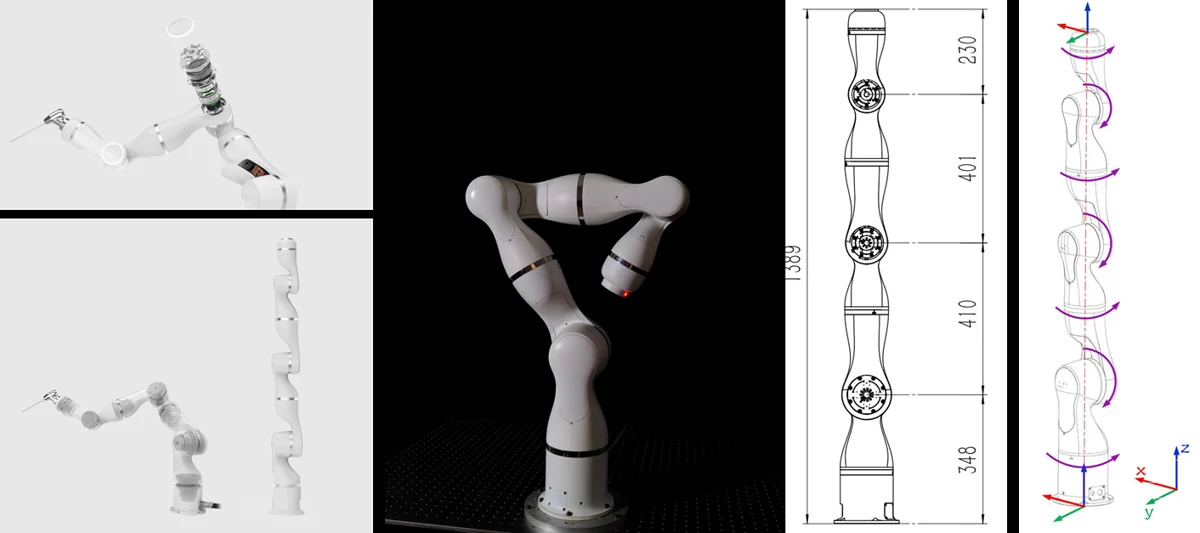
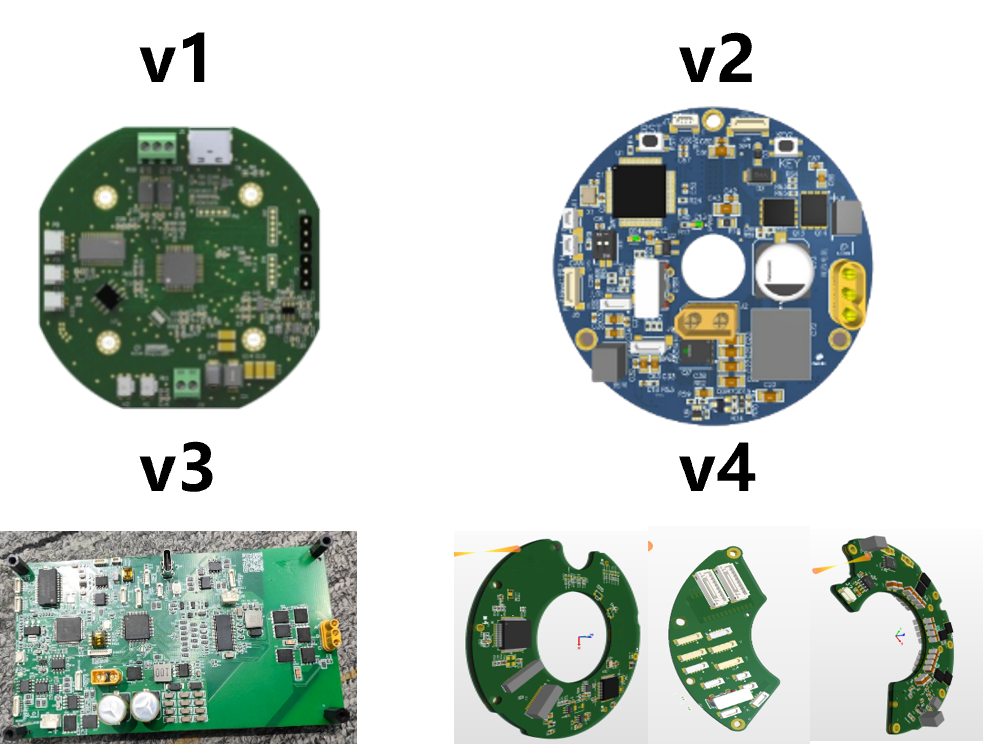
Where control meets hardware.
Four iterations of driver electronics for position tracking, compliant response, and collision detection.
With Chuanzhi Gao, You Wan & Yunxiang Jiang
Inside the driverConnecting algorithms,
machines, and people.
Servo and motion control, kinematics and dynamics, trajectory planning, and compliant motion control.
Robot control systemsHuman–robot interaction, dexterous manipulation, and vision–force hybrid control.
Collaborative roboticsSkill and imitation learning, robot system integration, and experimental applications.
Robot experimenterHardware, software,
and the experiments between.
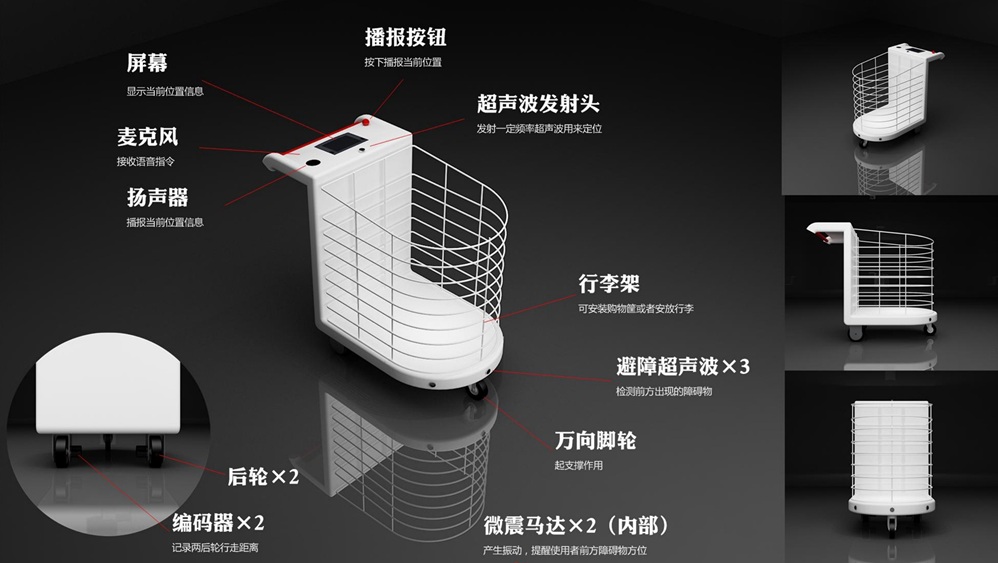
Mobile assistance for indoor walking.
System · HMI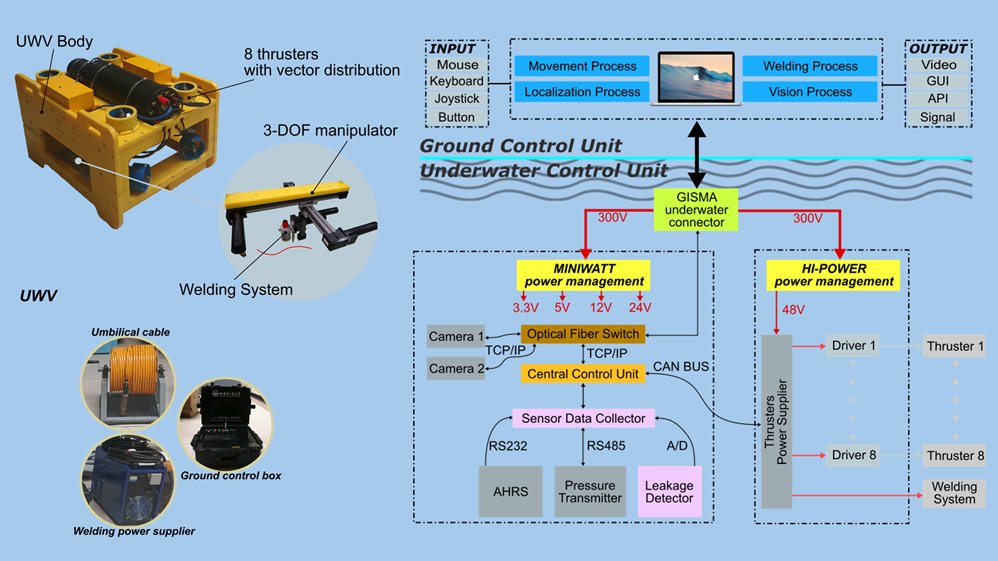
Localization and motion control for underwater welding.
System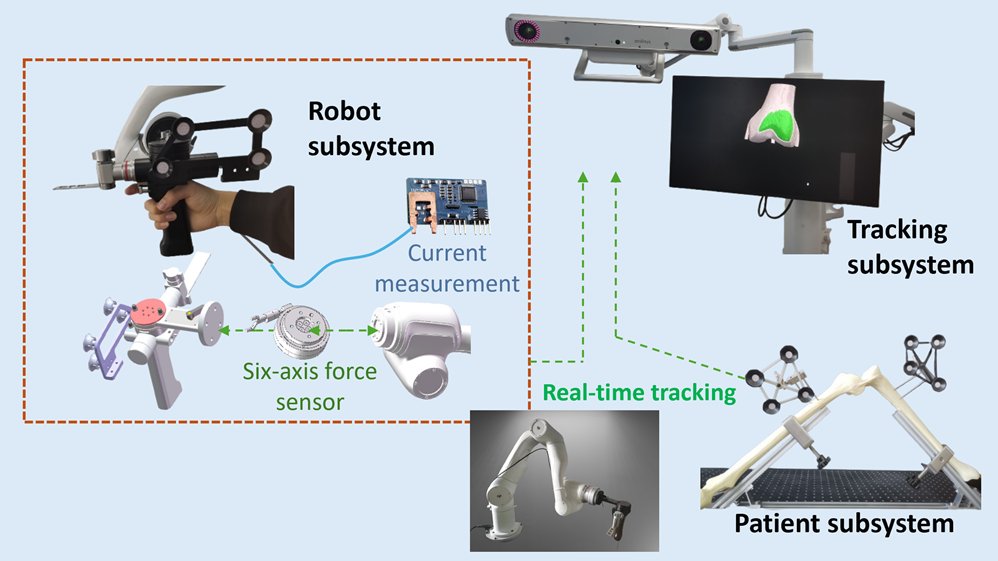
A robotic system for knee arthroplasty.
System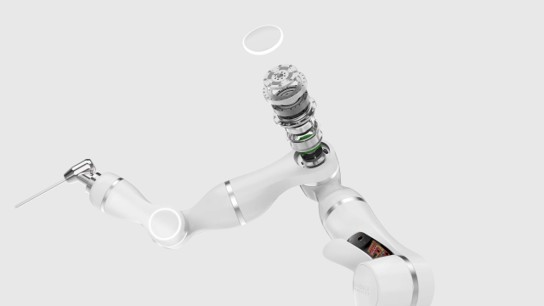
A seven-degree-of-freedom collaborative robot.
System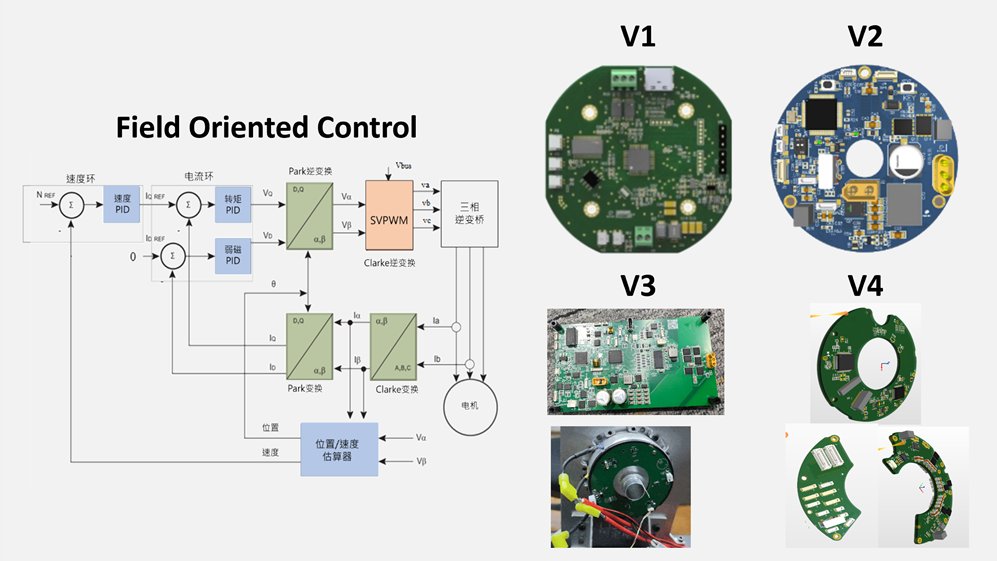
Integrated electronics for compliant robot motion.
System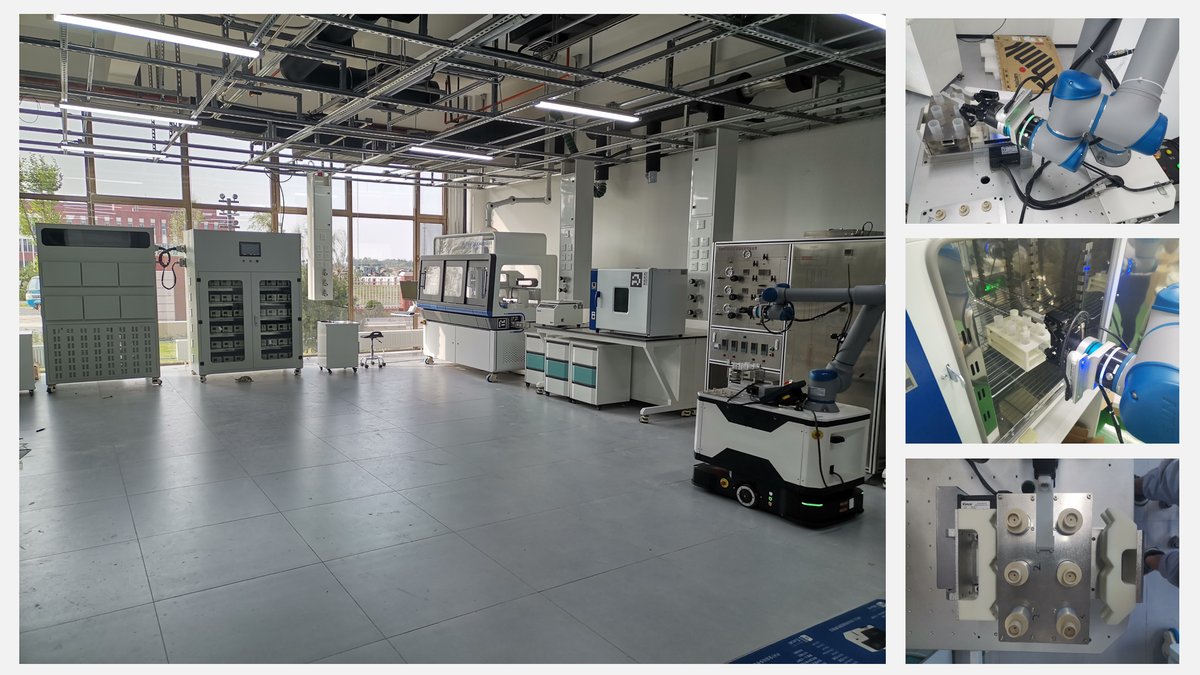
Robot systems for automated laboratory work.
System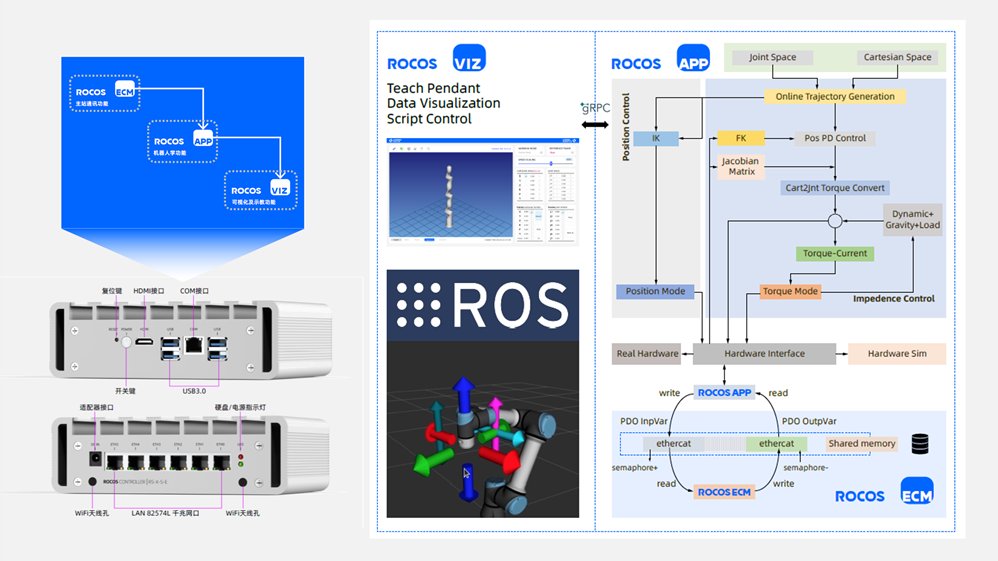
An open architecture for robot control and integration.
Control · HMI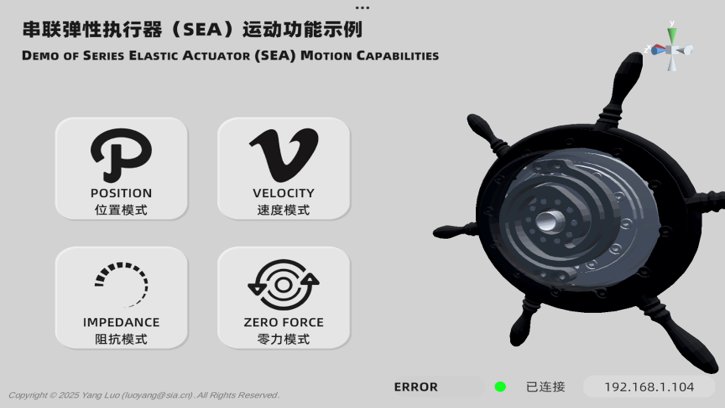
An application for series elastic actuator experiments.
HMI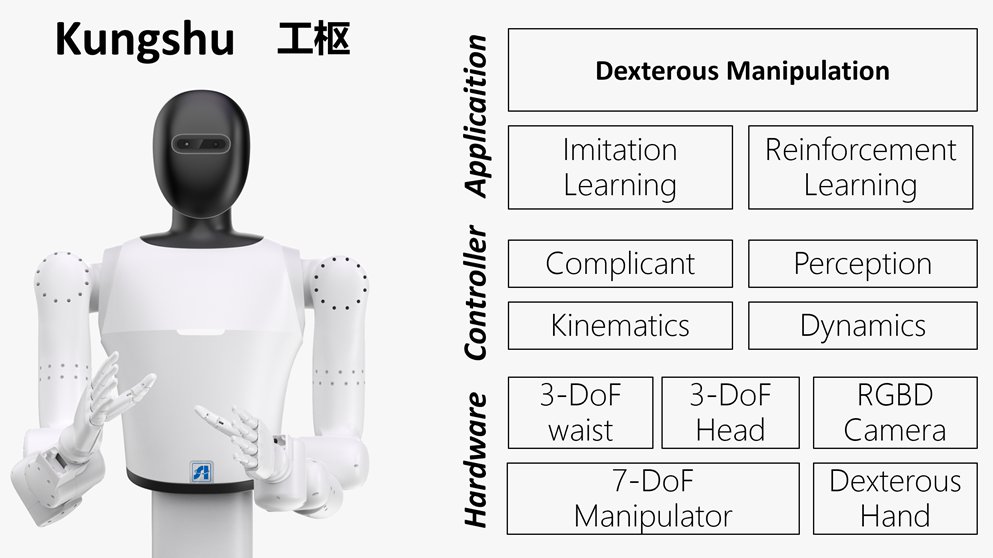
A control framework for humanoid robots.
Control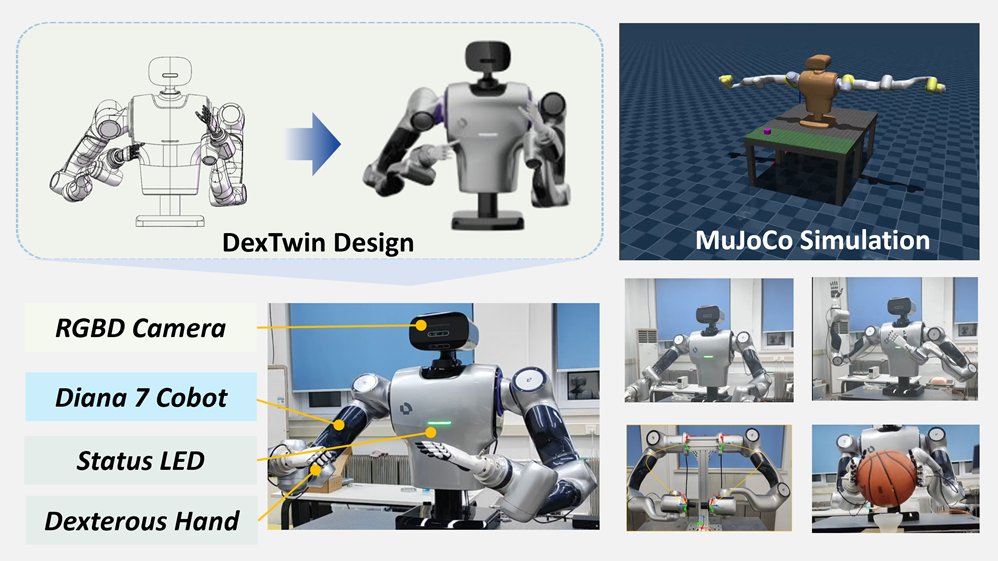
A robot controller for the Diana 7 platform.
System · Control
Software tools for force–torque sensing.
Control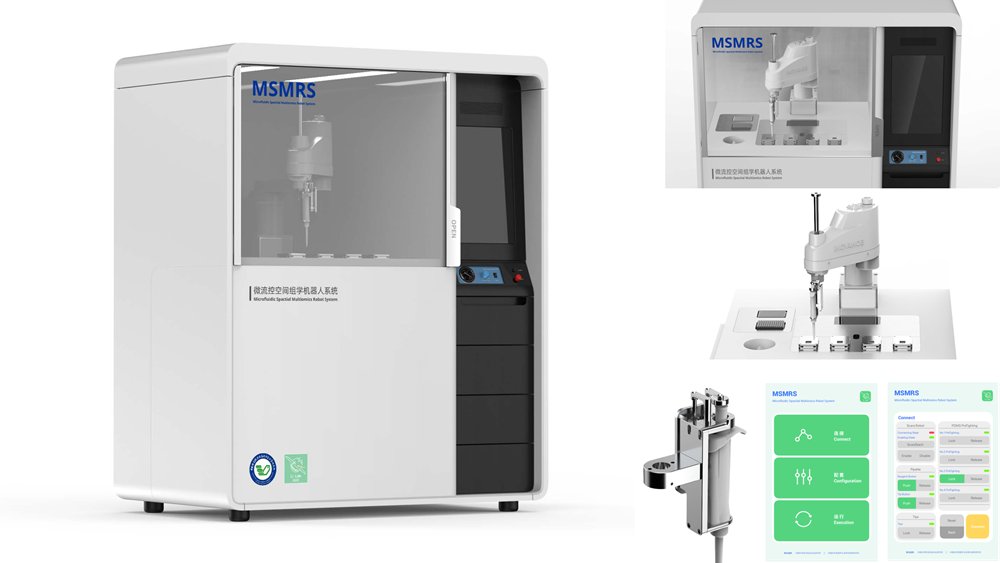
Motion control research and experimental demonstrations.
ControlNo projects match this category.
From EtherCAT devices to a visual teach pendant.
Explore three connected components.
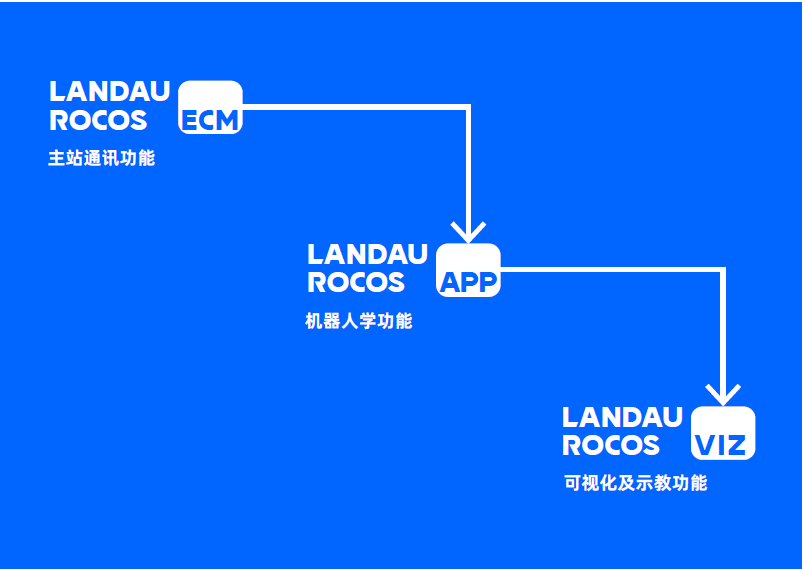
ROCOS-ECM is the EtherCAT master. It loads network topology from ENI files and provides access to bus data and servo drives.
It supplies the device-communication layer used by ROCOS-APP.
Explore ROCOS-ECM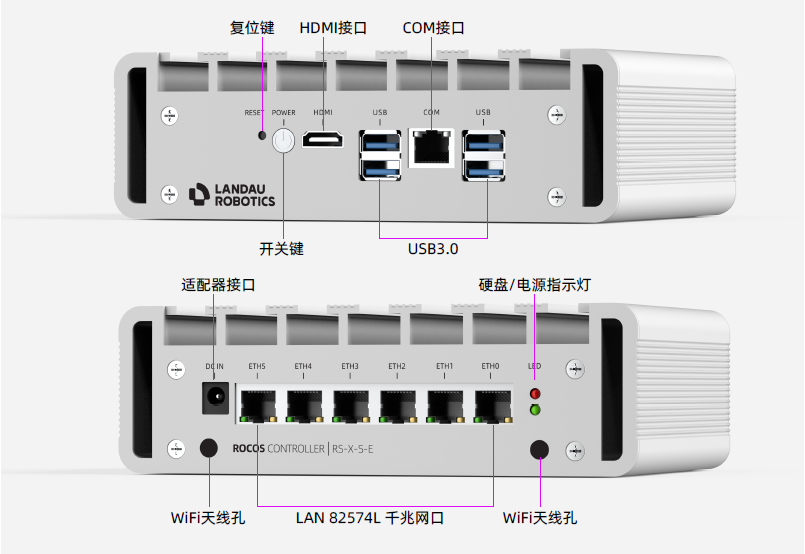
ROCOS-APP configures serial robots through URDF and provides robot motion, kinematics, and dynamics capabilities. Parallel mechanisms require custom algorithm modules.
Direct C++ and remote gRPC interfaces connect robot applications to the controller.
Explore ROCOS-APP
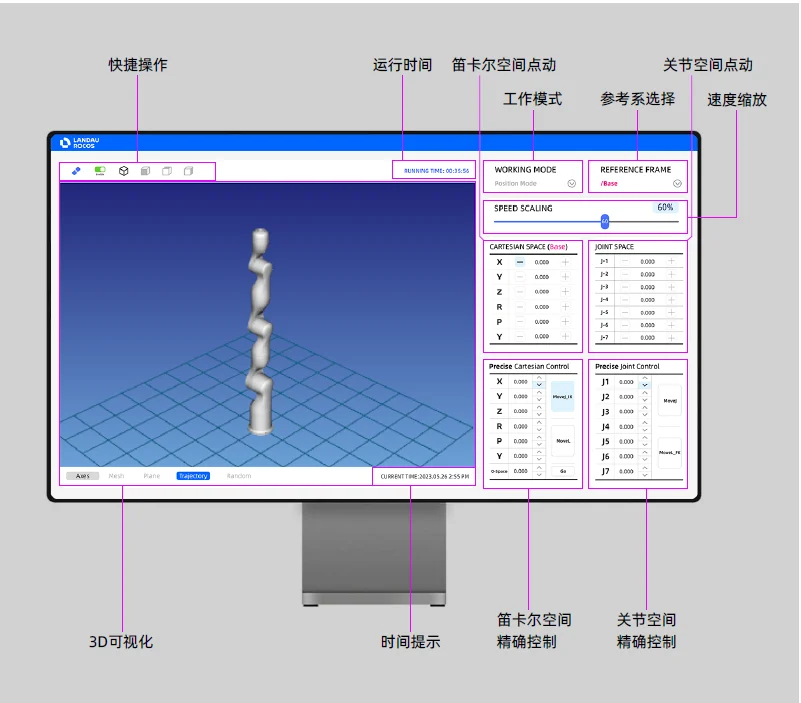
ROCOS-VIZ is a visual teach pendant with remote connection, robot visualization, curve display, and jog teaching.
The interface connects to the robot-control layer. Recorded demonstrations are available on the project page.
Explore ROCOS-VIZMethods, experiments, and results.
Explore the research behind the robots.
17 works
Newest first. Paper years follow the published volume; patent years follow the dates in the listed records.
Gao Z, Li Y, Luo Y*, et al. IEEE Sensors Journal, 2024, 24(3): 3513-3522. (Corresponding author)
@article{luo2024_5,
  title = {Tool Center Point Calibration via Posture-Sequence Particle Swarm Optimization},
  author = {Gao, Ziqi and Li, Yingli and Luo, Yang and Sun, Jincheng and Ying, Yuhan and Jiang, Yunxiang and Zhao, Xingang and Zhao, Yiwen},
  year = {2024},
  journal = {IEEE Sensors Journal},
  doi = {10.1109/jsen.2023.3344725},
  url = {https://doi.org/10.1109/jsen.2023.3344725},
  volume = {24},
  number = {3},
  pages = {3513--3522}
}赵忆文, 高子奇, 罗阳等. 2024-11-26, 中国, ZL202211409096.8 (发明专利)
赵忆文, 赵新刚, 高子奇, 姜运祥, 罗阳等. 2023-06-27, 中国, ZL202210538249.2 (发明专利)
赵忆文, 罗阳, 江超等. 2022-03-23, 中国, CN202210291939.2 (发明专利)
赵忆文, 罗阳等. 2022-9-19, 中国, CN202211137360.7 (发明专利)
赵忆文, 江超, 罗阳等. 2022-08-23, 中国, CN202211011429.1 (发明专利)
赵忆文, 孙锦程, 魏仁松, 罗阳等. 2022-7-11, 中国, CN202210811113.4 (发明专利)
赵忆文, 高子奇, 姜运祥, 罗阳等. 2022-11-21, 中国, CN202211452172.3 (发明专利)
赵忆文, 张元林, 姜运祥, 罗阳等. 2022-6-2, 中国, CN202210624184.3 (发明专利)
Hao Z, Luo Y, Huang C, et al. Small, 2021, 17(29): 2101508. (Co-first author)
@article{luo2021_3,
  title = {An Intelligent Graphene‐Based Biosensing Device for Cytokine Storm Syndrome Biomarkers Detection in Human Biofluids},
  author = {Hao, Zhuang and Luo, Yang and Huang, Cong and Wang, Ziran and Song, Guoli and Pan, Yunlu and Zhao, Xuezeng and Liu, Shaoqin},
  year = {2021},
  journal = {Small},
  doi = {10.1002/smll.202101508},
  url = {https://doi.org/10.1002/smll.202101508},
  volume = {17},
  number = {29},
  pages = {2101508}
}Su S, Luo Y, Yang K, et al. IEEE Sensors Journal, 2020, 20(11): 5818-5826.
@article{luo2020_4,
  title = {A Novel Camera Calibration Method Based on Multilevel-Edge-Fitting Ellipse-Shaped Analytical Model},
  author = {Su, Shun and Luo, Yang and Yang, Keke and Gao, Zhenyuan and Zhao, Yiwen and Zhao, Xingang and Song, Guoli},
  year = {2020},
  journal = {IEEE Sensors Journal},
  doi = {10.1109/jsen.2020.2972615},
  url = {https://doi.org/10.1109/jsen.2020.2972615},
  volume = {20},
  number = {11},
  pages = {5818--5826}
}Luo Y, Tao J, Sun H, et al. International Journal of Advanced Robotic Systems, 2019, 16(2): 1-11.
@article{luo2019_1,
  title = {A novel localization approach for underwater welding vehicles in spent fuel pools via attitude heading reference system and altimeters},
  author = {Luo, Yang and Tao, Jianguo and Sun, Hao and Hao, Zhuang and Li, Hao and Na, Qiang and Gao, Haibo and Ding, Liang and Deng, Zongquan},
  year = {2019},
  journal = {International Journal of Advanced Robotic Systems},
  doi = {10.1177/1729881419830540},
  url = {https://doi.org/10.1177/1729881419830540},
  volume = {16},
  number = {2},
  pages = {1--11}
}Luo Y, Tao J, Hao Z, et al. Advances in Mechanical Engineering, 2019, 11(11): 1-14.
@article{luo2019_2,
  title = {Centroid variability model–based control of HITUWV for automatic underwater welding with enhanced stability and accuracy},
  author = {Luo, Yang and Tao, Jianguo and Hao, Zhuang and Sun, Hao and Li, Zhandong and Gao, Haibo and Ding, Liang and Deng, Zongquan},
  year = {2019},
  journal = {Advances in Mechanical Engineering},
  doi = {10.1177/1687814019890219},
  url = {https://doi.org/10.1177/1687814019890219},
  volume = {11},
  number = {11},
  pages = {1--14}
}Luo Y, Tao J, Sun Q, et al. 2018 IEEE international conference on robotics and biomimetics (ROBIO). IEEE, 2018: 77-82.
@inproceedings{luo2018_8,
  title = {A New Underwater Robot for Crack Welding in Nuclear Power Plants},
  author = {Luo, Yang and Tao, Jianguo and Sun, Qingjie and Deng, Liping and Deng, Zongquan},
  year = {2018},
  booktitle = {2018 IEEE International Conference on Robotics and Biomimetics (ROBIO)},
  doi = {10.1109/robio.2018.8665279},
  url = {https://doi.org/10.1109/robio.2018.8665279},
  pages = {77--82}
}Luo Y, Tao J, Li Z, et al. 2017 IEEE International Conference on Robotics and Biomimetics (ROBIO). IEEE, 2017: 575-580.
@inproceedings{luo2017_6,
  title = {An accurate cavitation prediction thruster model based on Gaussian process regression},
  author = {Luo, Yang and Tao, Jianguo and Li, Zhandong and Ding, Liang and Deng, Zongquan and Sun, Hao and Song, Xingguo},
  year = {2017},
  booktitle = {2017 IEEE International Conference on Robotics and Biomimetics (ROBIO)},
  doi = {10.1109/robio.2017.8324478},
  url = {https://doi.org/10.1109/robio.2017.8324478},
  pages = {575--580}
}Luo Y, Tao J, Li Z, et al. 2017 12th International Conference on Computer Science and Education (ICCSE). IEEE, 2017: 791-794.
@inproceedings{luo2017_7,
  title = {A novel underwater localization algorithm fusing AHRS with altimeters},
  author = {Luo, Yang and Tao, Jianguo and Li, Zhandong and Ding, Liang and Deng, Zongquan and Zhao, Chenjian},
  year = {2017},
  booktitle = {2017 12th International Conference on Computer Science and Education (ICCSE)},
  doi = {10.1109/iccse.2017.8085602},
  url = {https://doi.org/10.1109/iccse.2017.8085602},
  pages = {791--794}
}Try another keyword, year, or type.
I work at the intersection
of software and robotics.
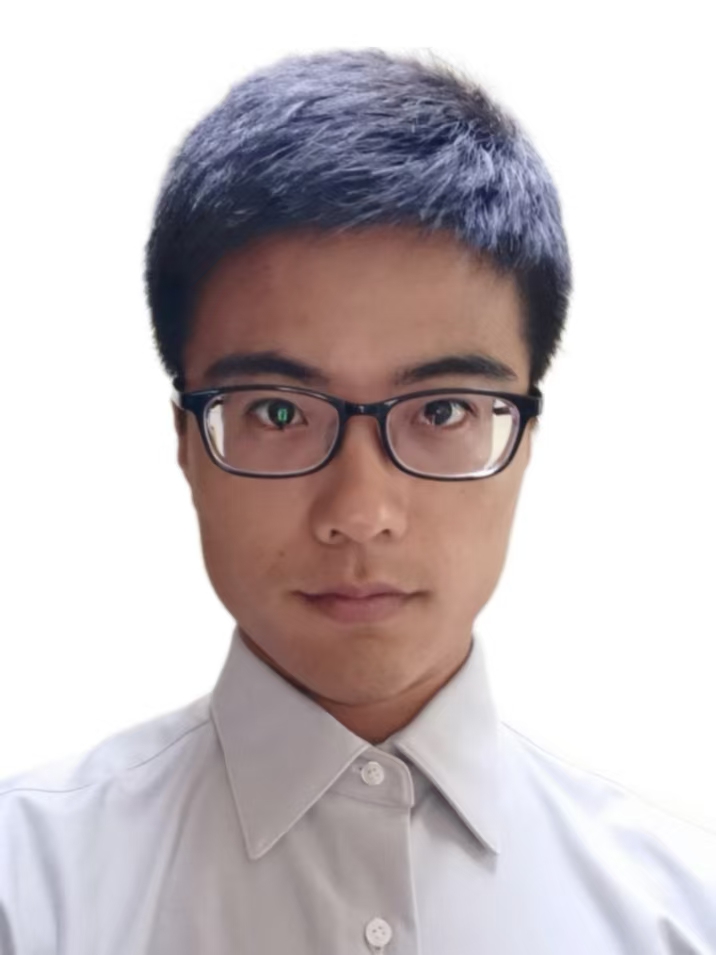
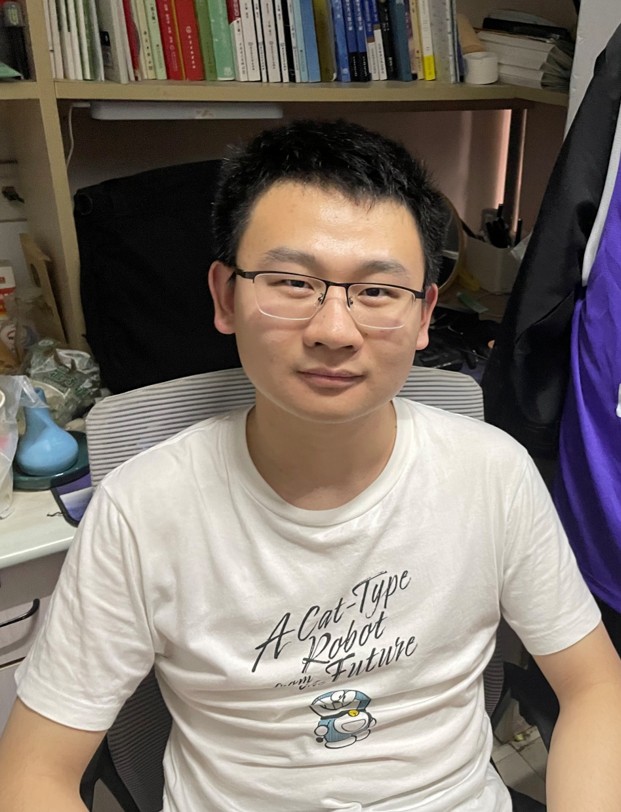
I'm Yang Luo, a robotics researcher at the Shenyang Institute of Automation, Chinese Academy of Sciences. I received my Ph.D. in 2019 from the State Key Laboratory of Robotics and Systems at Harbin Institute of Technology.
I enjoy designing robot architectures, programming motion, and contributing to open-source tools. My work connects robot system integration, motion control, trajectory planning, human–robot interaction, and dexterous manipulation.
Let's talk roboticsI value well-designed software architectures, clear design patterns, and maintainable code.
Open the map to load the location.